Note
Go to the end to download the full example code.
1.1-kW triple-three-phase SPMSM, CVC#
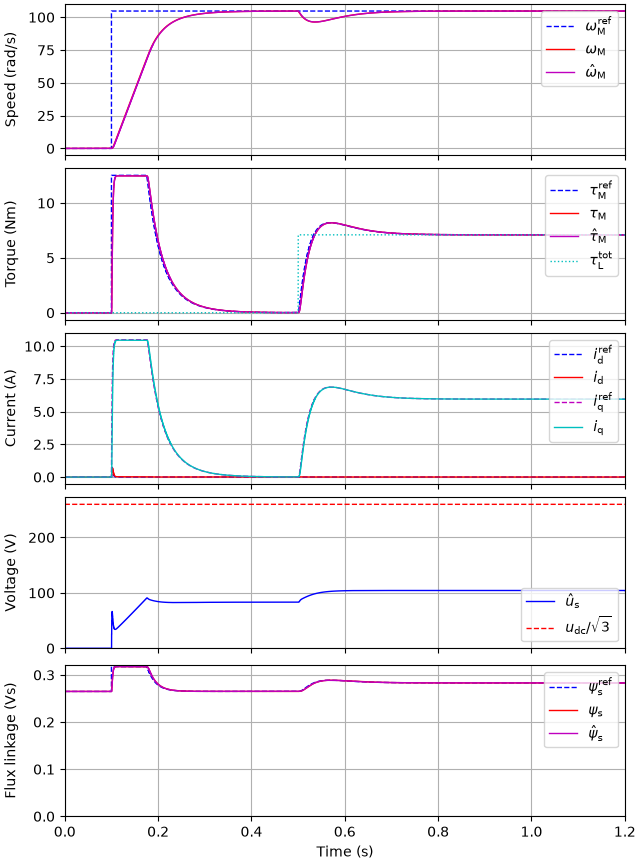
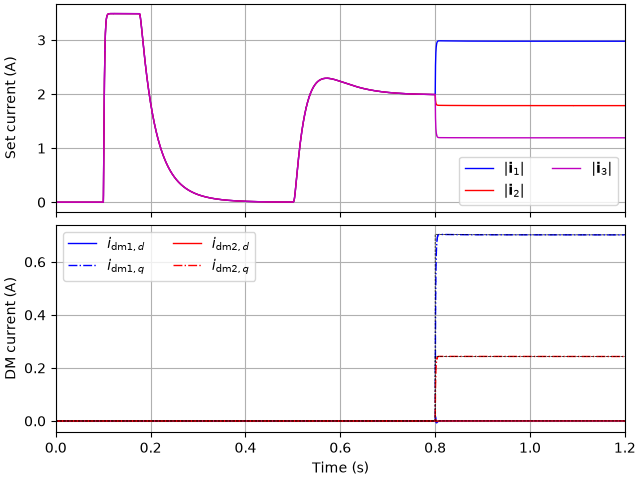
This example simulates current-vector control (CVC) of a nine-phase surface-mounted permanent-magnet synchronous machine (SPMSM) with three three-phase sets. The sets are displaced by 15°, which differs from the standard 20° of asymmetrical nine-phase machines. The machine parameters are from [1]. The common mode (CM) of the sets is controlled using the current-vector controller of motulator, parametrized with the parallel-connected equivalent machine, and the differential modes (DMs) are current-controlled. The current sharing between the sets is changed during the simulation.
from math import pi

import motulator.drive.control.sm as sm_control
import numpy as np

from motulator_multiphase import control, model, utils
Configure the system model. In the multi-stator model of [1], the flux linkage of the set k is psi_k = L_ls*i_k + M*sum(i_z) + psi_f. When all sets carry equal currents, the inductance of a set is L_ls + n_sets*M, which is used here. The model assumes identical sets, so the stator resistance and the leakage inductance of the sets 1 and 3 are used (the set 2 has 7.9 Ω and 10.3 mH).
n_sets = 3
R_s, L_ls, M, psi_f = 8.2, 18.5e-3, 10.5e-3, 0.265
L_s = L_ls + n_sets * M
par = model.SynchronousMachinePars(n_p=3, R_s=R_s, L_d=L_s, L_q=L_s, psi_f=psi_f)
theta_sets = np.radians([0, 15, 30])
machine = model.MultiThreePhaseMachine(
    par, L_ls=L_ls, n_sets=n_sets, theta_sets=theta_sets
)
mechanics = model.MechanicalSystem(J=0.0133)
converter = model.MultiThreePhaseConverter(u_dc=450, n_sets=n_sets)
sensors = model.DriveSensors(theta_M=model.Sensor())  # Sensored control
mdl = model.MultiThreePhaseDrive(machine, mechanics, converter, sensors=sensors)
Configure the control system. The current amplitude of each set is limited to 3.5 A, as in [1].
est_par = utils.to_parallel(par, n_sets)
cfg = sm_control.CurrentVectorControllerCfg(i_s_max=n_sets * 3.5, sensorless=False)
vector_ctrl = sm_control.CurrentVectorController(est_par, cfg)
dm_ctrl = control.DifferentialModeController(L_ls, n_sets=n_sets)
speed_ctrl = sm_control.SpeedController(J=0.0133, alpha_s=2 * pi * 4)
ctrl = control.MultiThreePhaseControlSystem(
    vector_ctrl, dm_ctrl, speed_ctrl, theta_sets=theta_sets
)
Set the speed reference, the rated load torque of 7.1 Nm, and the current sharing. The rated current is 1.4 A (rms) per set. In the end, the sets carry 50%, 30%, and 20% of the total current.
ctrl.set_speed_ref(lambda t: (t > 0.1) * 2 * pi * 1000 / 60)
mdl.mechanics.set_external_load_torque(lambda t: (t > 0.5) * 7.1)
ctrl.set_current_sharing(lambda t: [1.5, 0.9, 0.6] if t > 0.8 else n_sets * [1.0])
Simulate and plot the results. The first figure shows the CM quantities, where the current is the sum of the set currents, and the second one the currents of the sets and the DMs.
sim = model.Simulation(mdl, ctrl)
res = sim.simulate(t_stop=1.2)
utils.plot(res)
utils.plot_sets(res)
References
Total running time of the script: (0 minutes 12.059 seconds)