Native simulation#
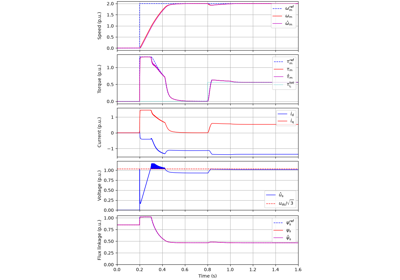
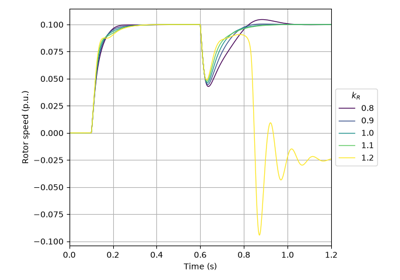
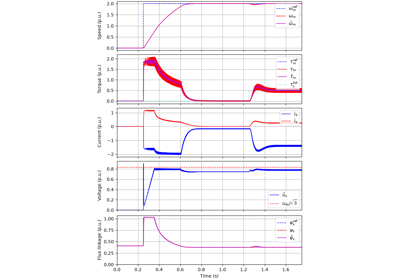
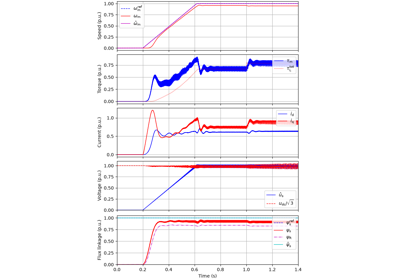
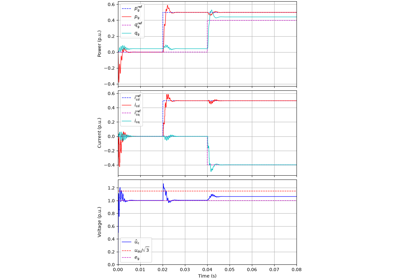
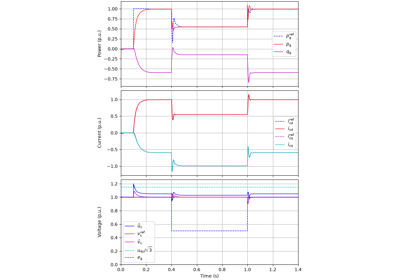
These examples simulate systems built in motulator natively, i.e., in C, with
motulator_export.native.Simulation. The systems are built as in the examples
of motulator, and only the simulation object is replaced; the results are those of
motulator and can be plotted with its plotting functions. The control system runs
the C port of the control algorithms of motulator, which is also used by the PLECS
and Simulink models of this package.