Note
Go to the end to download the full example code.
2.2-kW IPMSM, FVC#
This example simulates sensorless flux-vector control (FVC) of a 2.2-kW interior permanent-magnet synchronous machine (IPMSM) drive natively. The system is that of the motulator example 2.2-kW IPMSM, FVC. The same system is also simulated in motulator, and the run times and the differences are printed.
import time
from math import pi

import motulator.drive.control.sm as control
import numpy as np
from motulator.drive import model, utils

from motulator_export import native
Compute base values based on the nominal values.
nom = utils.NominalValues(U=370, I=4.3, f=75, P=2.2e3, tau=14)
base = utils.BaseValues.from_nominal(nom, n_p=3)
Configure the system model and the control system, as in the motulator example. The function builds a new system for each simulation.
def build_system() -> tuple[model.Drive, control.VectorControlSystem]:
    """Build the system model and the control system."""
    par = model.SynchronousMachinePars(
        n_p=3, R_s=3.6, L_d=0.036, L_q=0.051, psi_f=0.545
    )
    machine = model.SynchronousMachine(par)
    mechanics = model.MechanicalSystem(J=0.015)
    converter = model.VoltageSourceConverter(u_dc=540)
    mdl = model.Drive(machine, mechanics, converter)

    est_par = par  # Assume accurate model parameter estimates
    cfg = control.FluxVectorControllerCfg(i_s_max=1.5 * base.i, sensorless=True)
    vector_ctrl = control.FluxVectorController(est_par, cfg)
    speed_ctrl = control.SpeedController(J=0.015, alpha_s=2 * pi * 4)
    ctrl = control.VectorControlSystem(vector_ctrl, speed_ctrl)

    # Speed reference and external load torque
    ctrl.set_speed_ref(lambda t: (t > 0.2) * 2 * base.w_M)
    mdl.mechanics.set_external_load_torque(lambda t: (t > 0.8) * 0.7 * nom.tau)
    return mdl, ctrl
Simulate the system natively. Only the simulation object differs from the motulator example: native.Simulation replaces model.Simulation, and the results are plotted with the plotting functions of motulator.
mdl, ctrl = build_system()
sim = native.Simulation(mdl, ctrl)
start = time.perf_counter()
res = sim.simulate(t_stop=1.6)
t_native = time.perf_counter() - start
utils.plot(res, base)
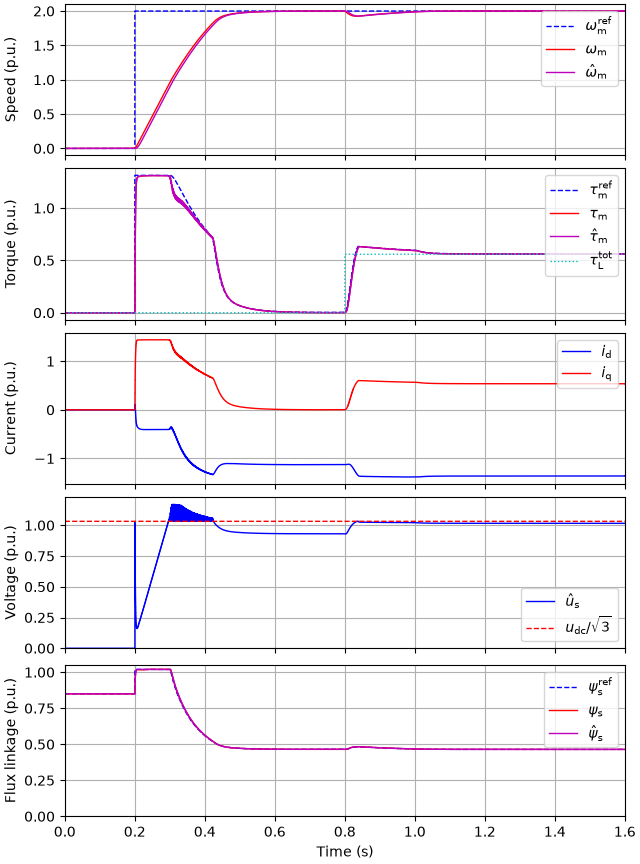
Simulate the same system in motulator. The native simulation takes the same solver steps, so the results agree to the rounding errors.
mdl, ctrl = build_system()
start = time.perf_counter()
res_py = model.Simulation(mdl, ctrl).simulate(t_stop=1.6)
t_py = time.perf_counter() - start

print(f"Run time: native {t_native:.2f} s, motulator {t_py:.1f} s")
diff = {
    "rotor speed (rad/s)": res.mdl.mechanics.w_M - res_py.mdl.mechanics.w_M,
    "stator current (A)": res.mdl.machine.i_s_ab - res_py.mdl.machine.i_s_ab,
    "torque reference (Nm)": res.ctrl.ref.tau_M - res_py.ctrl.ref.tau_M,
}
for name, d in diff.items():
    print(f"Maximum difference in the {name}: {np.max(np.abs(d)):.1e}")
Run time: native 1.12 s, motulator 7.7 s
Maximum difference in the rotor speed (rad/s): 2.3e-13
Maximum difference in the stator current (A): 5.8e-13
Maximum difference in the torque reference (Nm): 3.1e-13
Total running time of the script: (0 minutes 10.181 seconds)