Examples#
These examples demonstrate radial force control of six-phase bearingless synchronous machine drives. The two three-phase sets of the symmetrical six-phase winding produce both the torque and the radial force. In direct force control [1], the torque and the force are controlled directly by means of feedback linearization. For comparison, in current-based force control, the four-pole plane is controlled by a vector controller of motulator, and the force reference is converted to the current reference of the two-pole plane. In both cases, the rotor displacement can be controlled by an outer levitation controller. The magnetic model of the machine and of the controller is either linear or a gradient network trained on finite-element data [2], with or without the spatial harmonics. The examples with the gradient networks load the networks and the dataset from the folders trained_models and datasets of examples/, so they are run in a clone of the repository.
References
2.6-kW bearingless SyRM, current-based force control
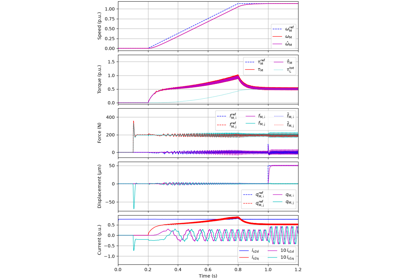
2.6-kW bearingless SyRM, GradNet from FEM data, levitation control
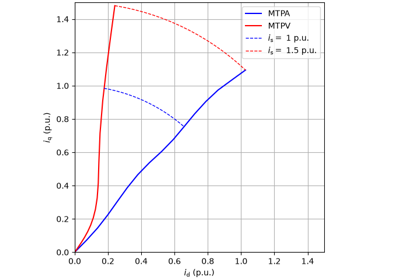
2.6-kW bearingless SyRM, GradNet from FEM data, direct force control
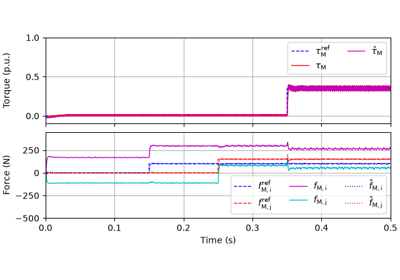
2.6-kW bearingless SyRM, comparison of control models in force control
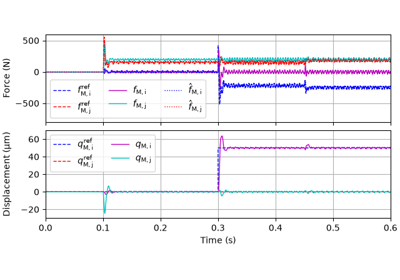
2.6-kW bearingless SyRM, comparison of control models in levitation control