Note
Go to the end to download the full example code.
2.6-kW bearingless SyRM, direct force control#
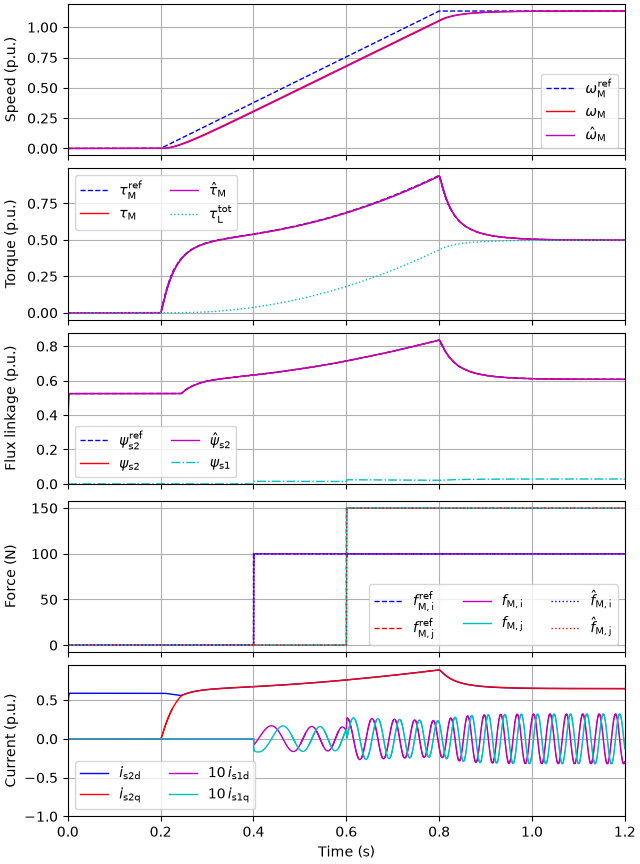
This example simulates direct radial force control of a 2.6-kW six-phase bearingless synchronous reluctance machine (SyRM) drive. The rotor is held at a fixed radial position by external bearings. The radial force references are those of [1], but the rotor angle and the rotor speed are estimated instead of measured. The machine and the controller use the same constant parameters, i.e., magnetic saturation and the unbalanced magnetic pull are omitted.
from math import pi

import numpy as np

from motulator_bearingless import control, model, utils
Compute base values based on the nominal values (just for figures).
nom = utils.NominalValues(U=220, I=12, f=50, P=2.6e3, tau=14.5)
base = utils.BaseValues.from_nominal(nom, n_p=2)
Configure the system model. The stator resistance is from [1]. The inductances and the radial force constants are scaled from the finite-element results of the same machine with separate windings [2] such that the rated torque is reached at about the rated current. The values are illustrative.
par = model.BearinglessSynchronousMachinePars(
    R_s=0.215, L_1=0.03, L_d=0.03, L_q=0.01, m_d=10.0, m_q=0.2
)
machine = model.BearinglessSynchronousMachine(par)
w_M_rated = 2 * pi * 1700 / 60
k = nom.tau / w_M_rated**2  # Quadratic load torque, rated torque at the rated speed
mechanics = model.MechanicalSystem(J=0.05, B_L=lambda w_M: k * abs(w_M))
converter = model.MultiThreePhaseConverter(u_dc=540)

# Rotor held at a fixed position, e.g., by active magnetic bearings. A static
# eccentricity of 30 µm and -20 µm could be set as follows:
radial = model.ExternalRotorPosition()
# radial.set_external_displacement(30e-6 - 20e-6j)

mdl = model.BearinglessDrive(machine, mechanics, radial, converter)
Configure the control system. The controller uses the same parameters as the model.
cfg = control.DirectForceControllerCfg(
    i_s_max=1.5 * base.i,
    psi_s_min=0.3,
    alpha_f=2 * pi * 300,
    alpha_i=2 * pi * 30,
    alpha_psi=2 * pi * 200,
    alpha_tau=2 * pi * 200,
    zeta=0.45,
    sensorless=True,
    T_s=125e-6,
)
force_ctrl = control.DirectForceController(par, cfg)
speed_ctrl = control.SpeedController(J=0.05, alpha_s=2 * pi * 4)
ctrl = control.DirectForceControlSystem(force_ctrl, speed_ctrl)
Set the speed and force references. The machine is magnetized during the first 0.2 s, after which the rotor is accelerated to the rated speed of 1700 r/min in 0.6 s against the quadratic load torque. The radial force references of 100 N and 150 N are applied during the acceleration at t = 0.4 s and t = 0.6 s.
ctrl.set_speed_ref(lambda t: min(max(t - 0.2, 0) / 0.6, 1) * w_M_rated)
ctrl.set_force_ref(lambda t: (t > 0.4) * 100 + 1j * (t > 0.6) * 150)
Create the simulation object, simulate, and plot the results.
sim = model.Simulation(mdl, ctrl)
res = sim.simulate(t_stop=1.2)
i_lims = (-1.0, 0.95)  # Room for the legends
utils.plot(res, base, y_lims=[None, None, None, None, i_lims])
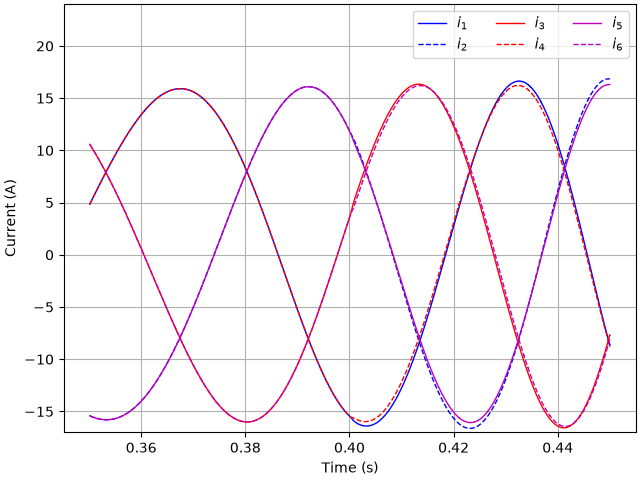
Plot the phase currents around the force step.
t_lims = (0.35, 0.45)
mask = (res.mdl.t > t_lims[0]) & (res.mdl.t < t_lims[1])
i_abc = utils.sixphase_currents(res.mdl.machine.i_c_ab[:, mask])
utils.plot_phase_currents(res.mdl.t[mask], i_abc, y_lims=(-17.0, 24.0))
print("Force at the end (N):", np.round(res.mdl.machine.f_M_ab[-1], 1))
Force at the end (N): (100+149.8j)
References
Total running time of the script: (0 minutes 21.631 seconds)