Note
Go to the end to download the full example code.
2.6-kW bearingless SyRM, comparison of control models in force control#
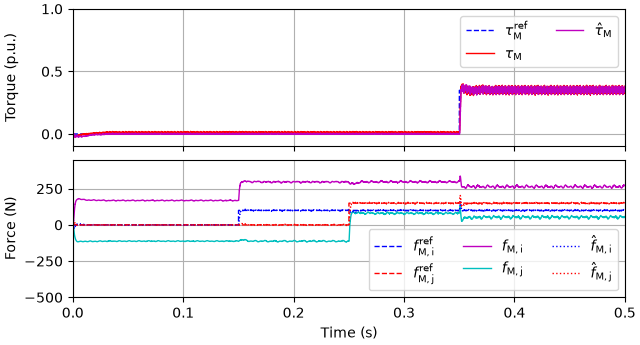
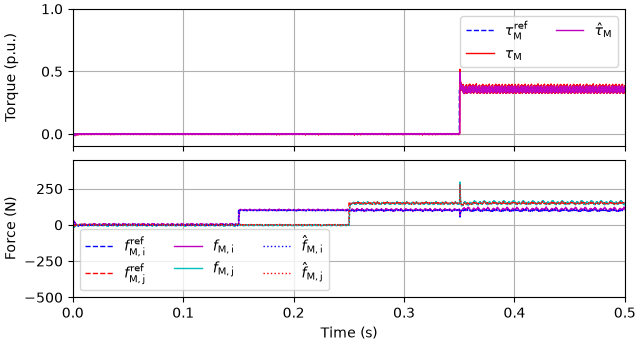
This example compares two parametrizations of the direct force controller [1] of a 2.6-kW six-phase bearingless synchronous reluctance machine (SyRM). The machine model is a GradNet current map with the spatial harmonics. The controller uses either constant parameters, computed at the rated peak current, or a GradNet flux map, which includes saturation and the unbalanced magnetic pull. The rotor runs at the rated speed, driven externally, and it is held at a fixed radial position. After magnetization, the radial force references are applied, followed by a torque reference step.
Compute base values based on the nominal values (just for figures).
nom = utils.NominalValues(U=220, I=12, f=50, P=2.6e3, tau=14.5)
base = utils.BaseValues.from_nominal(nom, n_p=2)
Load the magnetic models and compute the constant parameters from the flux map.
p = Path(__file__).resolve().parent if "__file__" in globals() else Path.cwd()
R_s = 0.215  # Stator resistance from [#Das2026]_
path = "trained_models/bsyrm_fem_curr_map_harm_softmax_d128.npz"
current_map = gn.CurrentMapWithHarmonics(gn.load_gradnet(p / path))
par = model.SpatialSaturatedBearinglessSynchronousMachinePars(R_s, current_map)

path = "trained_models/bsyrm_fem_flux_map_softmax_d128.npz"
est_flux_map = gn.FluxMap(gn.load_gradnet(p / path))
est_par = control.SaturatedBearinglessSynchronousMachinePars(
    R_s, psi_s_fcn=est_flux_map
)
est_par_lin = est_par.linearized(12 + 12j)
print(est_par_lin)
BearinglessSynchronousMachinePars(R_s=0.215, L_1=0.021501361436779196, L_d=0.03010432806595612, L_q=0.007563175729237954, m_d=11.346180847731612, m_q=-0.21198113390961698)
Configure the simulation, a static displacement as in [1].
w_M_rated = 2 * pi * 1700 / 60
q_M = 30e-6 - 20e-6j


def simulate(par_c: control.BearinglessMagneticModel):
    """Simulate the drive with the given control model."""
    machine = model.BearinglessSynchronousMachine(par)
    mechanics = model.ExternalRotorSpeed()
    mechanics.set_external_rotor_speed(w_M_rated)
    radial = model.ExternalRotorPosition()
    radial.set_external_displacement(q_M)
    converter = model.MultiThreePhaseConverter(u_dc=540)
    sensors = model.BearinglessDriveSensors(w_M=model.Sensor(), theta_M=model.Sensor())
    mdl = model.BearinglessDrive(machine, mechanics, radial, converter, sensors)
    cfg = control.DirectForceControllerCfg(i_s_max=25.5, psi_s_min=0.4)
    ctrl = control.DirectForceControlSystem(control.DirectForceController(par_c, cfg))
    ctrl.set_torque_ref(lambda t: (t > 0.35) * 0.7 * nom.tau)
    ctrl.set_force_ref(lambda t: (t > 0.15) * 100 + 1j * (t > 0.25) * 150)
    return model.Simulation(mdl, ctrl).simulate(t_stop=0.5)


res_lin = simulate(est_par_lin)
res_map = simulate(est_par)
for name, res in (("Constant parameters", res_lin), ("Flux map", res_map)):
    mask = res.mdl.t > 0.42
    print(
        f"{name}: mean force {np.mean(res.mdl.machine.f_M_ab[mask]):.1f} N, "
        f"mean torque {np.mean(res.mdl.machine.tau_M[mask]):.2f} Nm"
    )
Constant parameters: mean force 263.9+53.6j N, mean torque 10.06 Nm
Flux map: mean force 106.7+152.4j N, mean torque 10.25 Nm
Plot the results of the constant-parameter controller. Its force estimate omits the unbalanced magnetic pull, whose force at this displacement is of the same order as the force reference. Since the force is not measured, the error remains in the steady state.
Plot the results of the flux-map controller. The force estimate includes the pull, and the ripple comes from the spatial harmonics of the machine model.
utils.plot(res_map, base, ["torque", "force"], y_lims=y_lims)
References
Total running time of the script: (0 minutes 21.251 seconds)