Induction Machines#
This document describes continuous-time induction machine models of the motulator.drive.model package.
Induction Machine Model#
The induction machine model consists of the stator resistance, the magnetic model, and the rotor cage. In general coordinates rotating at \(\omegac\) (see Coordinate Transformation), the voltage equations are
where \(\us\) is the stator voltage, \(\is\) is the stator current, \(\psis\) is the stator flux linkage, and \(\Rs\) is the stator resistance. The rotor quantities are defined similarly. The rotor winding of a cage machine is short-circuited, i.e., the rotor voltage is \(\mathbf{u}_\mathrm{r} = 0\). The deep-bar effect can be modeled by replacing the rotor resistance \(\Rr\) with the cage impedance, see Cage Impedance. The electrical angular speed of the rotor is \(\omegam = \np \omegaM\), where \(\omegaM\) is the mechanical angular speed of the rotor and \(\np\) is the number of pole pairs.
The magnetic model gives the stator and rotor currents as functions of the stator and rotor flux linkages, see Magnetic Model. Without spatial harmonics, the electromagnetic torque is
where the star operator denotes the complex conjugate.
The model is implemented in the motulator.drive.model.InductionMachine class in rotor coordinates (\(\omegac = \omegam\)), in which the cage impedance is time invariant and the magnetic model can depend on the electrical rotor angle \(\thetam\), whose state equation is \(\D\thetam/\D t = \omegam\). Figure 1 shows the block diagram of the model in these coordinates. Since the machine is fed and observed from stator coordinates, the stator voltage and the stator current are transformed accordingly, in the same way as in the synchronous machine model, see Figure 3 in Synchronous Machine Model.

Figure 1: Block diagram of the induction machine model in rotor coordinates. The magnetic model gives the currents and the torque, and it depends on the angle \(\thetam\) only if spatial harmonics are modeled. The cage impedance \(Z_\mathrm{c}(s)\) reduces to the rotor resistance \(\Rr\), if the deep-bar effect is omitted.#
Figure 1: Block diagram of the induction machine model in rotor coordinates. The magnetic model gives the currents and the torque, and it depends on the angle \(\thetam\) only if spatial harmonics are modeled. The cage impedance \(Z_\mathrm{c}(s)\) reduces to the rotor resistance \(\Rr\), if the deep-bar effect is omitted.#
The rotor quantities can be scaled freely, since the rotor of a cage machine has no terminals. The class uses the scaling of its parameters, e.g., the rotor quantities are those of the inverse-Γ model if the inverse-Γ parameters are used.
Magnetic Model#
Γ Model#
Figure 2 shows the Γ-equivalent circuit model of an induction machine, which readily extends to include the main-flux saturation [Slemon, 1989]. Its parameters are defined in the motulator.drive.model.InductionMachinePars class.

Figure 2: Γ model of an induction machine in stator coordinates (denoted by the superscript s). The stator inductance can be parametrized to be a nonlinear function of the stator flux magnitude, \(\Ls = \Ls(\abspsis)\).#
Figure 2: Γ model of an induction machine in stator coordinates (denoted by the superscript s). The stator inductance can be parametrized to be a nonlinear function of the stator flux magnitude, \(\Ls = \Ls(\abspsis)\).#
The stator and rotor currents, respectively, are
where \(\Ls\) is the stator inductance, \(L_\ell\) is the leakage inductance, and \(\gamma\) is the magnetic coupling factor
The main-flux saturation is modeled using a nonlinear stator inductance \(\Ls = \Ls(\abspsis)\) where \(\abspsis = |\psis|\) [Qu et al., 2012, Slemon, 1989]. The saturable stator inductance can be unambiguously characterized using simple no-load tests. It also properly takes into account the effect of the load variations on the saturation state. Notice that the nonlinear stator inductance only appears in (4). See also examples 2.2-kW saturated IM, CVC and 2.2-kW saturated IM, FVC.
Inverse-Γ Model#
Figure 3 shows the inverse-Γ model of an induction machine. This model is commonly used in control applications for more straightforward implementation. Its constant parameters are defined in the motulator.drive.model.InductionMachineInvGammaPars class, which can be used both in control methods and to parametrize the motulator.drive.model.InductionMachine model.

Figure 3: Inverse-Γ model of an induction machine in stator coordinates. If main-flux saturation is included, the parameters become nonlinear functions of the stator flux magnitude, \(\Lsgm(\abspsis)\), \(\RR(\abspsis)\), and \(\LM(\abspsis)\).#
Figure 3: Inverse-Γ model of an induction machine in stator coordinates. If main-flux saturation is included, the parameters become nonlinear functions of the stator flux magnitude, \(\Lsgm(\abspsis)\), \(\RR(\abspsis)\), and \(\LM(\abspsis)\).#
The stator and rotor flux linkages, respectively, are
where \(\Lsgm\) is the leakage inductance and \(\LM\) is the magnetizing inductance. The rotor flux linkage \(\psiR = \gamma\psir\) and the rotor current \(\iR = \ir/\gamma\) are scaled with respect to the Γ model, and the rotor resistance is \(\RR\). If the magnetic saturation is omitted, the inverse-Γ model is mathematically identical to the Γ model [Slemon, 1989]. The parameters can be transformed as
where \(\gamma\) is defined in (4).
While the inverse-Γ model is convenient for control, incorporating magnetic saturation directly into it is challenging. A more practical approach is to map the saturation effects from the Γ model using the factor \(\gamma\) in (4). As a result, the inverse-Γ model parameters become flux-dependent: \(\Lsgm(\abspsis)\), \(\RR(\abspsis)\), and \(\LM(\abspsis)\). The motulator.drive.model.InductionMachinePars class provides these inverse-Γ parameters at a given stator flux linkage magnitude through its method inv_gamma_pars, which the control systems evaluate at the estimated flux in each sampling period. This enables saturation-aware control methods (see example 2.2-kW saturated IM, FVC).
Using the stator flux linkage and the stator current as state variables, the nonlinear state-space form becomes
where \(\Lsgm\), \(\RR\), \(\LM\), \(\alpha = \RR/\LM\) are nonlinear functions of the stator flux magnitude. Saturation introduces a transient voltage term
This voltage term only appears during changes in the stator-flux magnitude. When the transient voltage term is included, the inverse-Γ model (7) is mathematically identical to the original nonlinear Γ model. However, in control methods, the transient voltage term can typically be neglected.
General Magnetic Model#
In general, the magnetic model is a current map, i.e., a map from the flux linkages to the currents. The map is lossless if the currents are the gradient of the field energy with respect to the flux linkages, i.e.,
where \(W\) is the field energy multiplied by 2/3 and the components of the flux linkages are defined by \(\psis = \psi_\mathrm{sd} + \jj\psi_\mathrm{sq}\) and \(\psir = \psi_\mathrm{rd} + \jj\psi_\mathrm{rq}\). Without spatial harmonics, \(W\) depends only on the magnitudes of the flux linkages and on the angle between them. As an example, the Γ model with constant inductances corresponds to
A current map can be given as a function using the motulator.drive.model.SaturatedInductionMachinePars class, e.g., for modeling the saturation of the leakage flux or the mutual saturation between the main flux and the leakage flux [Tuovinen et al., 2010]. With spatial harmonics (e.g., due to the slots), \(W\) in rotor coordinates also depends on the electrical rotor angle \(\thetam\), and the torque is
Such a map, including the torque, can be given using the motulator.drive.model.SpatialSaturatedInductionMachinePars class.
Cage Impedance#
Due to the eddy currents in the rotor bars, the rotor resistance increases and the rotor leakage inductance decreases with the frequency of the rotor current (deep-bar effect). This effect can be modeled by replacing the rotor resistance with the cage impedance [Mölsä et al., 2020]
in rotor coordinates, i.e., a ladder circuit of series resistances and shunt inductances, terminated with the last resistance, as shown in Figure 4. Hence, \(R_0\) is the DC resistance and \(L_0\) is the DC inductance of the cage. The rotor voltage equation in (1) then becomes
in rotor coordinates (\(\omegac = \omegam\)), where \(s\) is the differential operator. The flux linkages of the inductances are additional state variables.
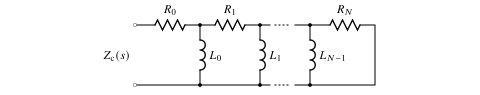
Figure 4: Cage impedance \(Z_\mathrm{c}(s)\) as a ladder circuit of the order \(N\).#
Figure 4: Cage impedance \(Z_\mathrm{c}(s)\) as a ladder circuit of the order \(N\).#
For rectangular rotor bars, the elements are [Mölsä et al., 2020]
The cage impedance is defined in the motulator.drive.model.CageImpedance class, which can be given as the rotor resistance to the Γ-model parameters and to the general magnetic model classes. The inverse-Γ parameters of the Γ-model class, used in control, are then those of the low-frequency equivalent \(Z_\mathrm{c}(s) \approx R_0 + sL_0\), i.e., the DC inductance of the cage adds to the leakage inductance. See also the example 5.6-kW deep-bar IM, direct-on-line start.
Core Losses#
Eddy-current core losses can be optionally modeled by means of a constant core-loss conductance \(\Gc\), connected between the stator resistance and the magnetic model, i.e., in parallel with the stator inductance in the Γ model [Qu et al., 2012]. In this case, the current given by the magnetic model is denoted by \(\isp\) and the stator current becomes
where \(\us - \Rs\is\) is the voltage across the core-loss conductance. The corresponding core losses are \((3/2)\Gc|\us - \Rs\is|^2\). Notice that the torque is produced by the current \(\isp\), i.e., the core-loss current does not contribute to the torque. By default, \(\Gc = 0\), i.e., the core losses are omitted.
Note
For notational simplicity, \(\Gc = 0\) is assumed elsewhere in this documentation, i.e., \(\is = \isp\). Otherwise, the magnetic model and the expressions derived from it hold as such, if the current \(\isp\) is used in place of \(\is\).
Flux and Torque Dynamics#
Using the Γ model with the rotor resistance, the flux and torque dynamics can be written as [Tiitinen et al., 2025]
where \(\abspsis = |\psis|\) is the flux magnitude, \(\omegarb = \Rr/L_\ell\) is the breakdown angular slip frequency, and \(\omegar\) is the slip angular frequency. These dynamics are valid also for saturated machines where \(\Ls = \Ls(\abspsis)\), and they are also independent of the coordinate system. In this documentation, the sum of the electrical angular speed and the slip angular frequency
is referred to as the stator angular frequency, with this definition being agnostic to the coordinate system and defined also in transient states.
The flux and torque dynamics can be easily transformed to the inverse-Γ form by substituting \(\psir = \psiR/\gamma\), \(L_\ell = \Lsgm/\gamma\), and \(\Rr = \RR/\gamma^2\). Compare also to (15) in the Synchronous Machine Model document.
Note
Substituting \(\omegar = \omegarb\) in (16) yields the breakdown condition \(\IM\{\psis\psir^*\} = \RE\{\psis\psir^*\}\). Applying this condition in the Γ model and assuming the steady state results in the breakdown torque expression