Note
Go to the end to download the full example code.
5.6-kW PM-SyRM, GradNet from measured data, FVC#
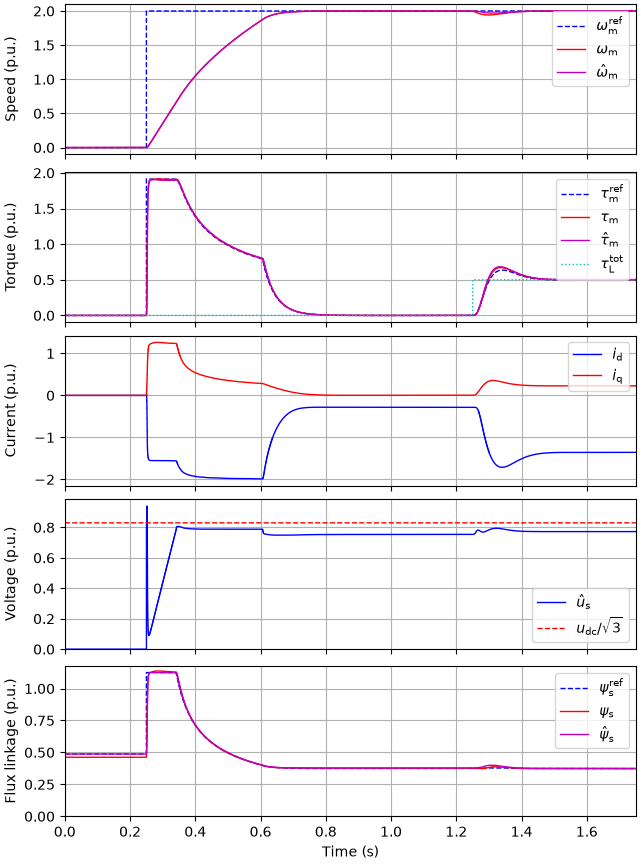
This example simulates flux-vector control (FVC) of a 5.6-kW PM synchronous reluctance machine (Baldor ECS101M0H7EF4) drive. GradNet models trained on measured data without spatial harmonics are used for both the machine model and the control system. The models are trained with the related package motulator-gradnet.
Compute base values based on the nominal values.
nom = utils.NominalValues(U=460, I=8.8, f=60, P=5.6e3, tau=29.7)
base = utils.BaseValues.from_nominal(nom, n_p=2)
Determine the path of the current script.
Configure the system model using the GradNet current map, without spatial harmonics, trained on the measured dataset.
path = "trained_models/baldor_meas_curr_map_squareplus_d12_sub10.npz"
gradnet = gn.load_gradnet(p / path)
current_map = gn.CurrentMap(gradnet)
par = model.SaturatedSynchronousMachinePars(n_p=2, R_s=0.63, i_s_dq_fcn=current_map)

machine = model.SynchronousMachine(par)
mechanics = model.MechanicalSystem(J=0.05)
converter = model.VoltageSourceConverter(u_dc=540)
mdl = model.Drive(machine, mechanics, converter)
Configure the control system using the GradNet flux map, without spatial harmonics, trained on the measured dataset.
# Parametrize the estimated machine model
path = "trained_models/baldor_meas_flux_map_pnorm_d6_sub10.npz"
est_flux_map = gn.FluxMap(gn.load_gradnet(p / path))
est_par = control.SaturatedSynchronousMachinePars(
    n_p=2, R_s=0.63, psi_s_dq_fcn=est_flux_map
)

# Configure the control system
cfg = control.FluxVectorControllerCfg(
    i_s_max=2 * base.i, alpha_i=0, alpha_o=2 * np.pi * 8, J=0.05, sensorless=False
)
vector_ctrl = control.FluxVectorController(est_par, cfg)
speed_ctrl = control.SpeedController(J=0.05, alpha_s=2 * np.pi * 4)
ctrl = control.VectorControlSystem(vector_ctrl, speed_ctrl)
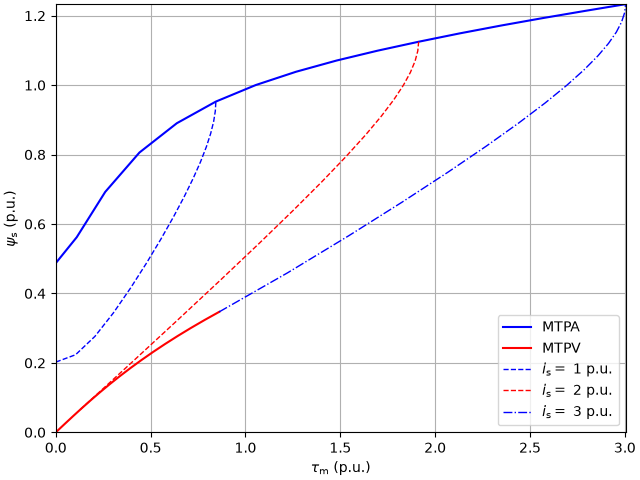
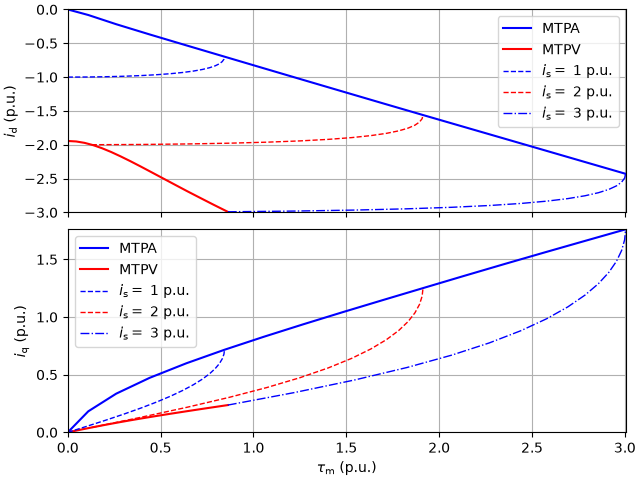
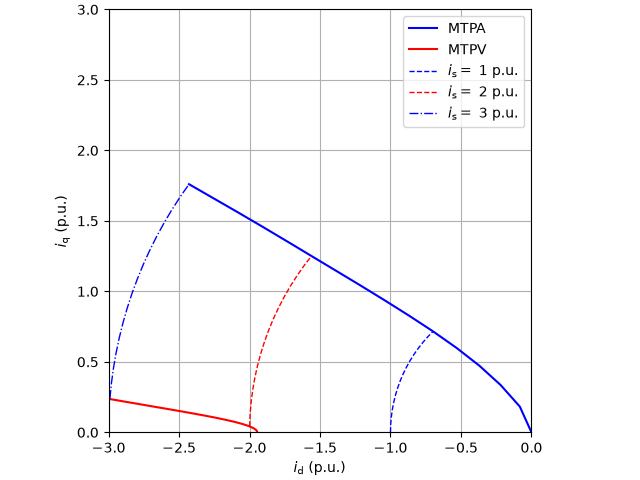
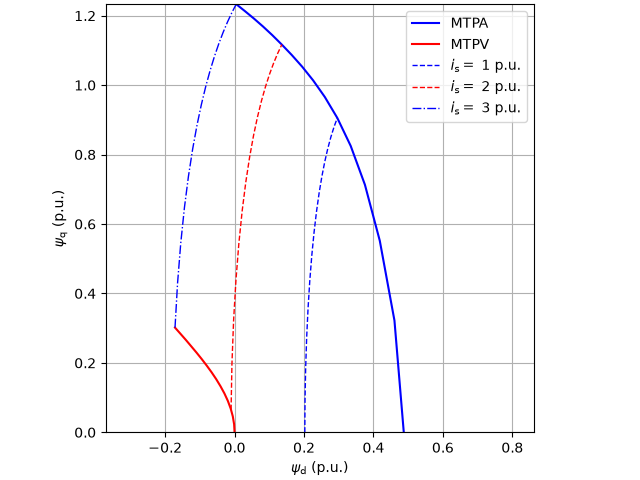
Visualize the control loci.
i_s_vals = [1, 2, 3]  # Current values for the plots
mc = utils.MachineCharacteristics(est_par)
mc.plot_flux_vs_torque(i_s_vals, base)
mc.plot_current_vs_torque(i_s_vals, base)
mc.plot_current_loci(i_s_vals, base)
mc.plot_flux_loci(i_s_vals, base)
Set the speed reference and the external load torque.
ctrl.set_speed_ref(lambda t: (t > 0.25) * 2 * base.w_M)
mdl.mechanics.set_external_load_torque(lambda t: (t > 1.25) * 0.5 * base.tau)
Create the simulation object, simulate, and plot the results in per-unit values.
sim = model.Simulation(mdl, ctrl)
res = sim.simulate(t_stop=1.75)
utils.plot(res, base)
Total running time of the script: (0 minutes 8.587 seconds)